Preprint
❝ citations
Scene coordinate and correspondence learning for image-based localization
arXiv (Cornell University), 2018

Abstract
Scene coordinate regression has become an essential part of current camera re-localization methods. Different versions, such as regression forests and deep learning methods, have been successfully applied to estimate the corresponding camera pose given a single input image. In this work, we propose to regress the scene coordinates pixel-wise for a given RGB image by using deep learning. Compared to the recent methods, which usually employ RANSAC to obtain a robust pose estimate from the established point correspondences, we propose to regress confidences of these correspondences, which allows us to immediately discard erroneous predictions and improve the initial pose estimates. Finally, the resulting confidences can be used to score initial pose hypothesis and aid in pose refinement, offering a generalized solution to solve this task.
Interactive explainer
Coming soon. An interactive Slidev walkthrough of this paper — with live, explorable figures — will appear here.
Authors: set
slidev: in this page's front matter to the deployed deck URL.Research themes
Keywords
Deep LearningUncertaintyComputer VisionPose Estimation
Lab authors


Cite (BibTeX)
@article{bui2018scene,
 author = {Bui, Mai and Albarqouni, Shadi and Ilic, Slobodan and Navab, Nassir},
 journal = {arXiv preprint arXiv:1805.08443},
 title = {Scene coordinate and correspondence learning for image-based localization},
 year = {2018}
}
Related publications
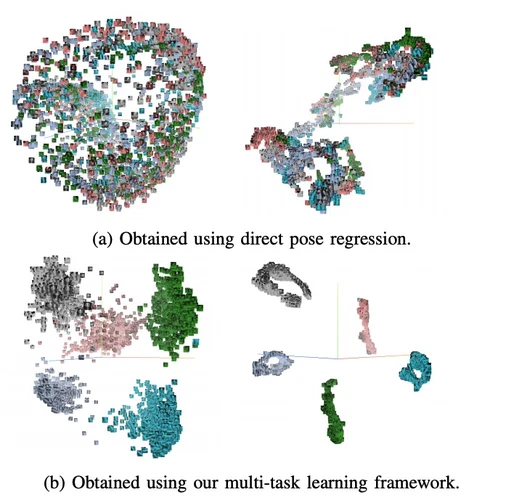
When regression meets manifold learning for object recognition and pose estimation
2018 IEEE International Conference on Robotics and Automation (ICRA), 2018
X-Ray PoseNet: 6 DoF pose estimation for mobile X-Ray devices
2017 IEEE Winter Conference on Applications of Computer Vision (WACV), 2017
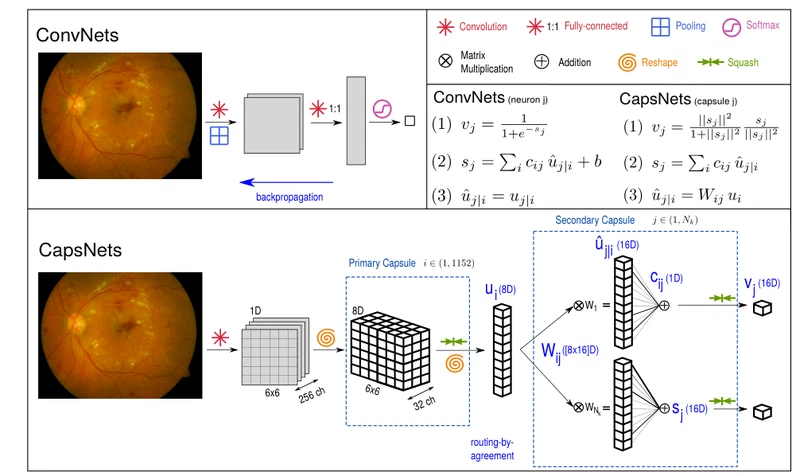
Capsule networks against medical imaging data challenges
Lecture notes in computer science, 2018
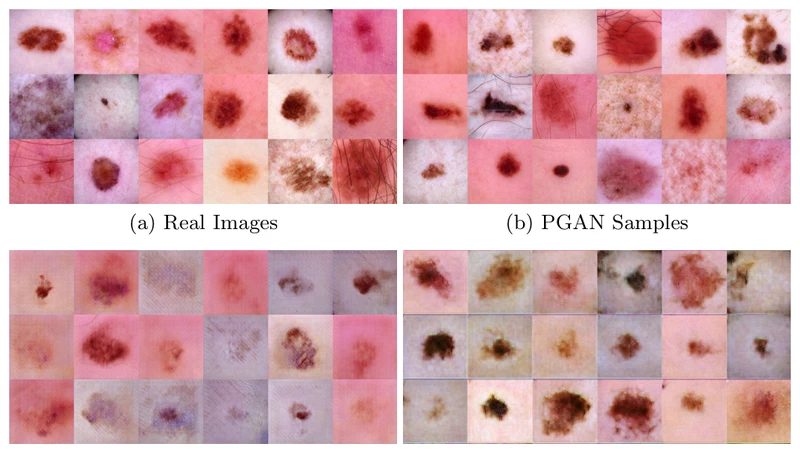
Generating highly realistic images of skin lesions with GANs
Lecture notes in computer science, 2018