Workshop
❝ citations
Adversarial Networks for Camera Pose Regression and Refinement
Proceedings of the IEEE International Conference on Computer Vision Workshops, 2019
Abstract
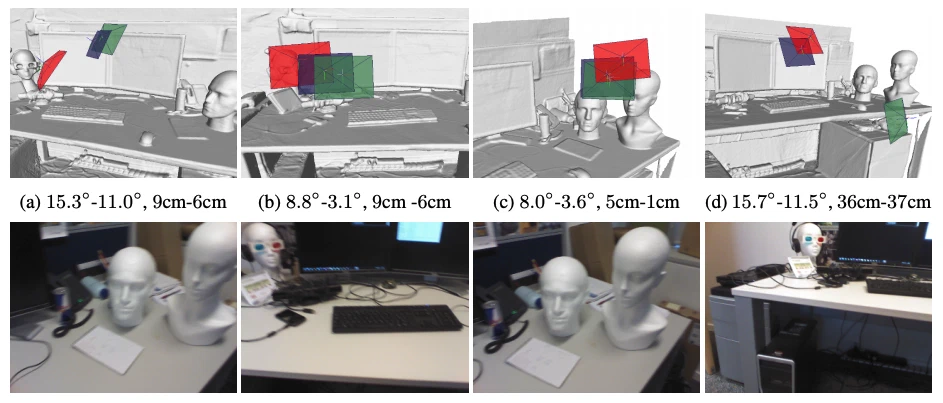
Despite recent advances on the topic of direct camera pose regression using neural networks, accurately estimating the camera pose of a single RGB image still remains a challenging task. To address this problem, we introduce a novel framework based, in its core, on the idea of implicitly learning the joint distribution of RGB images and their corresponding camera poses using a discriminator network and adversarial learning. Our method allows not only to regress the camera pose from a single image, however, also offers a solely RGB-based solution for camera pose refinement using the discriminator network. Further, we show that our method can effectively be used to optimize the predicted camera poses and thus improve the localization accuracy. To this end, we validate our proposed method on the publicly available 7-Scenes dataset improving upon the results of direct camera pose regression methods.
Interactive explainer
Coming soon. An interactive Slidev walkthrough of this paper — with live, explorable figures — will appear here.
Authors: set
slidev: in this page's front matter to the deployed deck URL.Research themes
Keywords
Computer VisionPose EstimationUncertaintyGenerative Adversarial Networks


Cite (BibTeX)
@inproceedings{bui2019adversarial,
 author = {Bui, Mai and Baur, Christoph and Navab, Nassir and Ilic, Slobodan and Albarqouni, Shadi},
 booktitle = {Proceedings of the IEEE International Conference on Computer Vision Workshops},
 pages = {0--0},
 title = {Adversarial Networks for Camera Pose Regression and Refinement},
 year = {2019}
}
Related publications
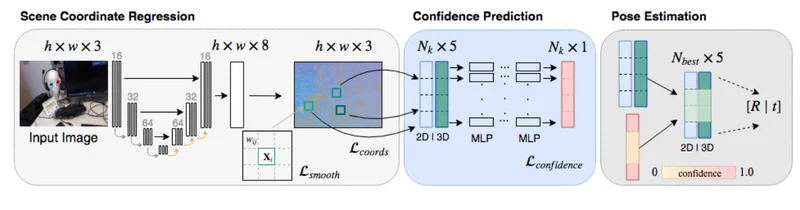
Scene coordinate and correspondence learning for image-based localization
arXiv (Cornell University), 2018
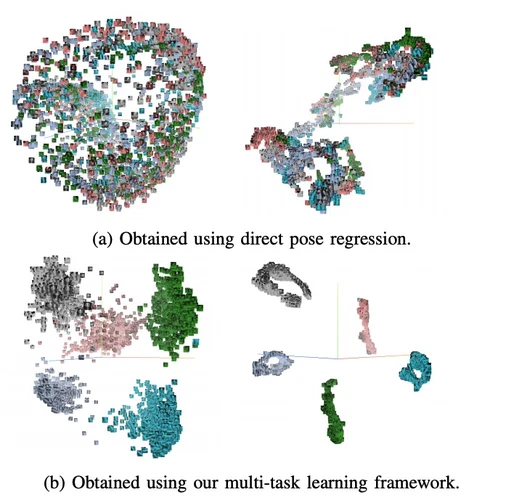
When regression meets manifold learning for object recognition and pose estimation
2018 IEEE International Conference on Robotics and Automation (ICRA), 2018
X-Ray PoseNet: 6 DoF pose estimation for mobile X-Ray devices
2017 IEEE Winter Conference on Applications of Computer Vision (WACV), 2017
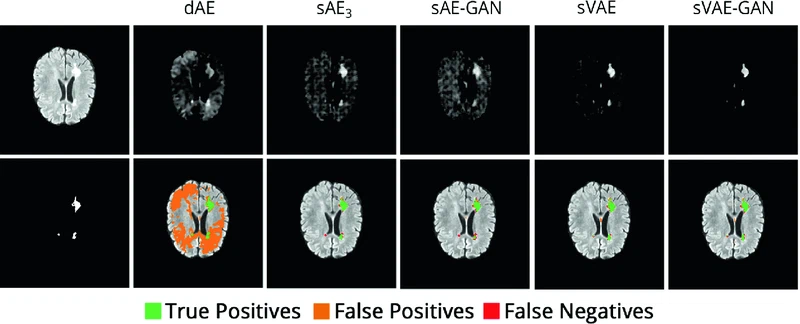
Deep autoencoding models for unsupervised anomaly segmentation in brain MR images
Brainlesion: Glioma, Multiple Sclerosis, Stroke and Traumatic Brain Injuries — BrainLes 2018 workshop @ MICCAI, Lecture Notes in Computer Science, 2019