Patent
❝ 3 citations
Determining a pose of an object in the surroundings of the object by means of multi-task learning
, February 2022
Abstract
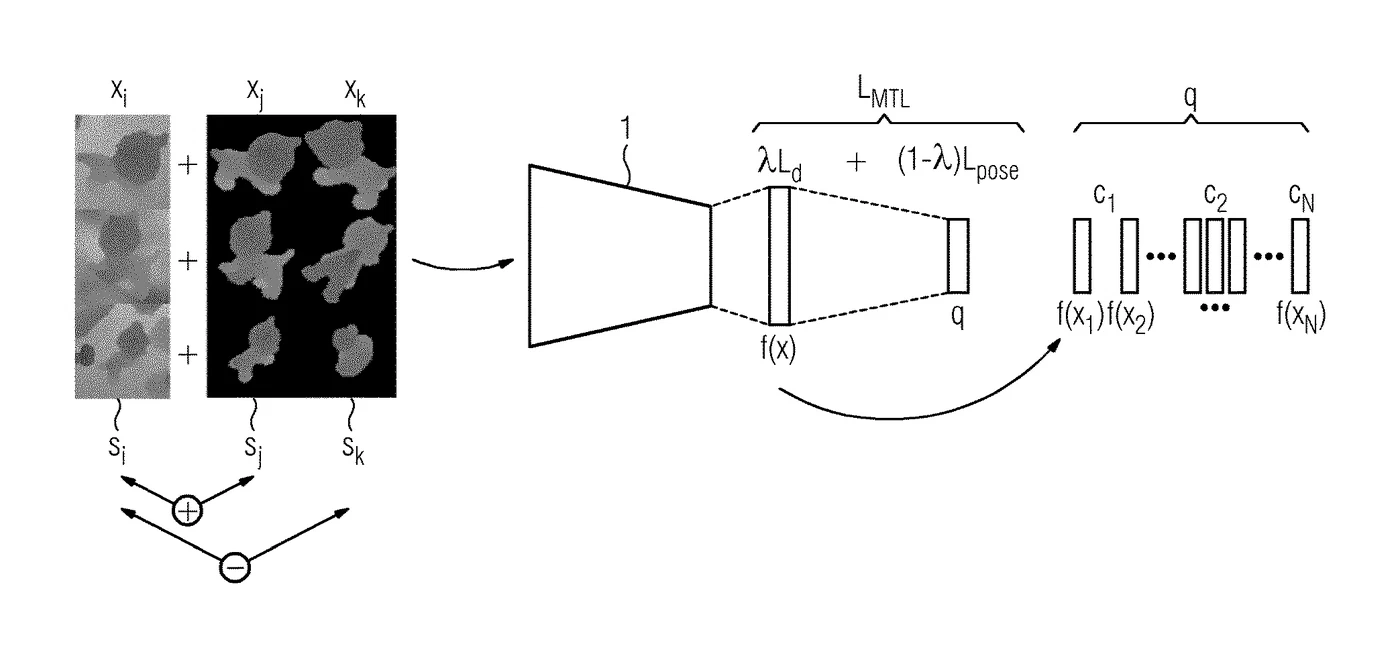
Various embodiments include a method for determining a pose of an object in its surroundings comprising: using an optical capture device to capture the object and its surroundings as current recording; determining the pose of the object using optical image analysis; and using a neural network to ascertain the pose of the object. The neural network is taught with multi-task learning using pose regression and descriptor learning using a triplet-wise loss function and a pair-wise loss function. The pose regression uses quaternions. Determining the triplet-wise loss function includes using a dynamic margin term. Determining the pair-wise loss function includes an anchoring function.
Interactive explainer
Coming soon. An interactive Slidev walkthrough of this paper — with live, explorable figures — will appear here.
Authors: set
slidev: in this page's front matter to the deployed deck URL.Research themes
Research areas
Funded by
Lab authors


Cite (BibTeX)
@misc{zakharov2022determining,
 author = {Zakharov, Sergey and Albarqouni, Shadi and Bui, Linda Mai and Ilic, Slobodan},
 month = {February~8},
 note = {US Patent 11,244,475},
 title = {Determining a pose of an object in the surroundings of the object by means of multi-task learning},
 year = {2022}
}