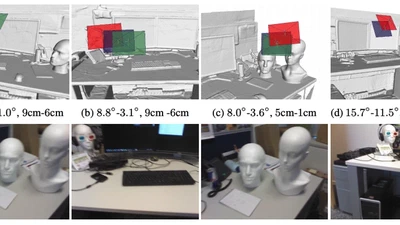
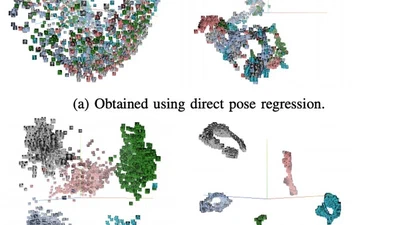
We present a multimodal camera relocalization framework that captures ambiguities and uncertainties with continuous mixture models defined on the manifold of camera poses. In …
Despite recent advances on the topic of direct camera pose regression using neural networks, accurately estimating the camera pose of a single RGB image still remains a challenging …
In this work, we propose a method for object recognition and pose estimation from depth images using convolutional neural networks. Previous methods addressing this problem rely on …
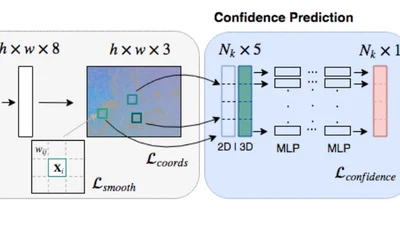
Scene coordinate regression has become an essential part of current camera re-localization methods. Different versions, such as regression forests and deep learning methods, have …
Precise reconstruction of 3D volumes from X-ray projections requires precisely pre-calibrated systems where accurate knowledge of the systems geometric parameters is known ahead. …
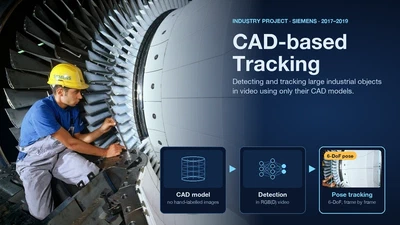
Industry project with Siemens AG (Corporate Technology) on learning the pose of large industrial objects and of the camera or X-ray device observing them, using their CAD models as …
Privacy — With your consent we use Google Analytics to understand how our website is used (IP addresses anonymised).
You can change your choice at any time via “Cookie settings” in the footer. Privacy policy